How it works
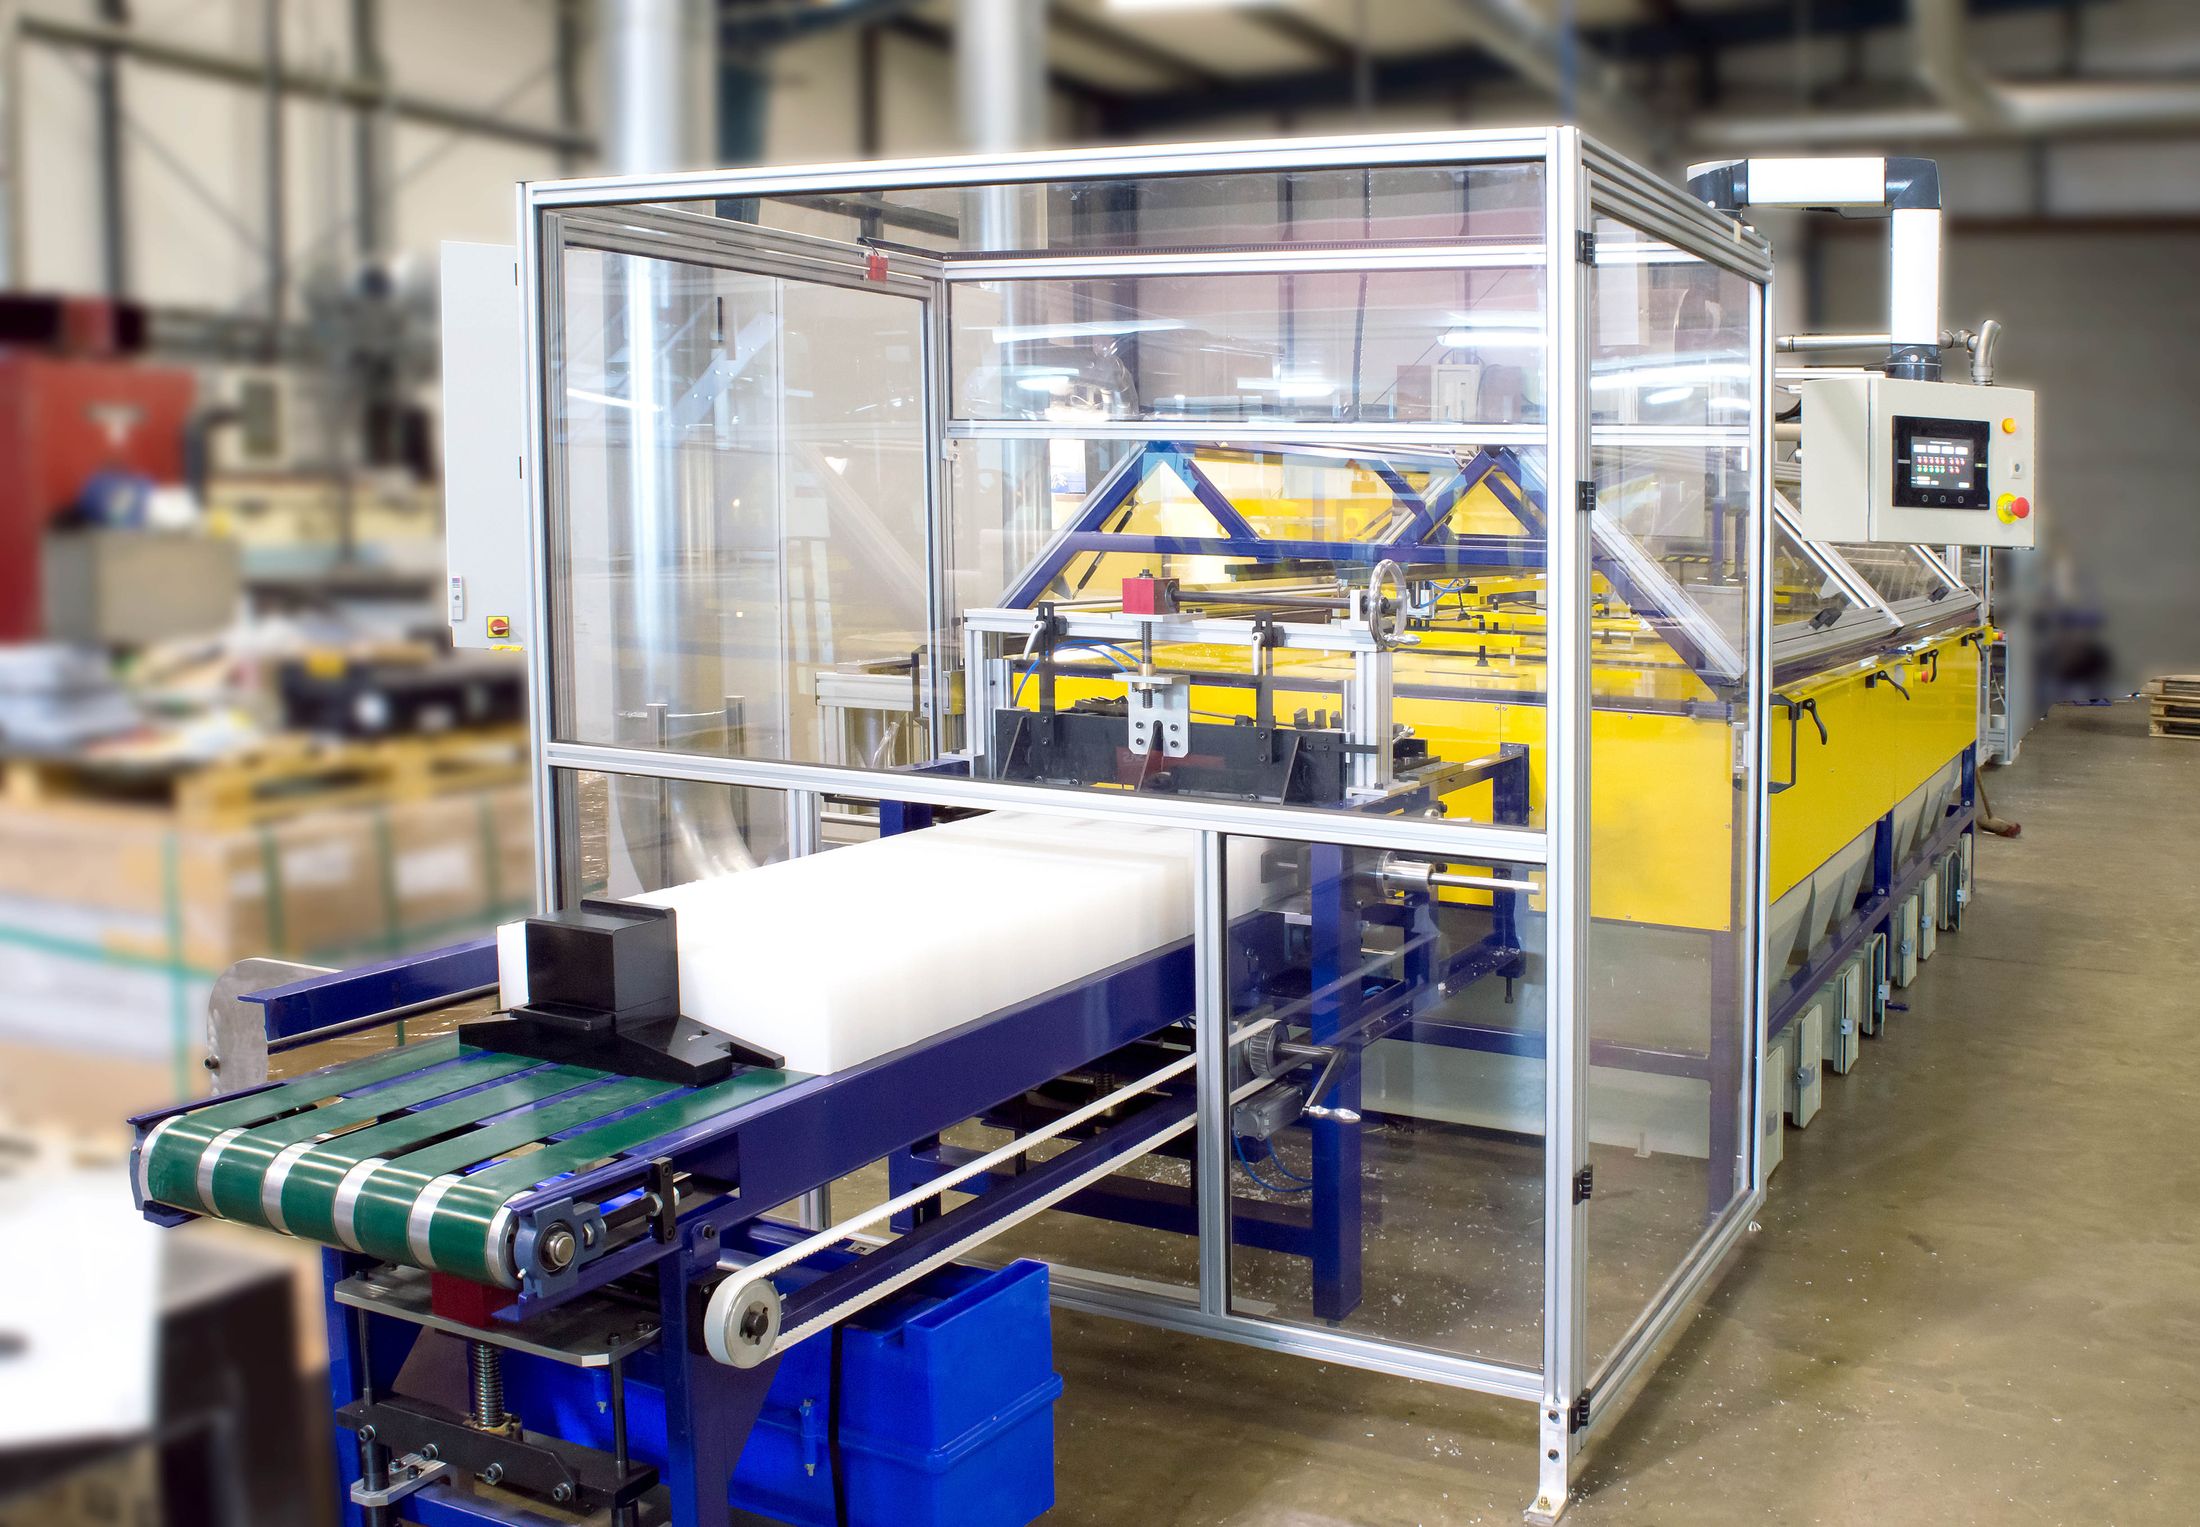
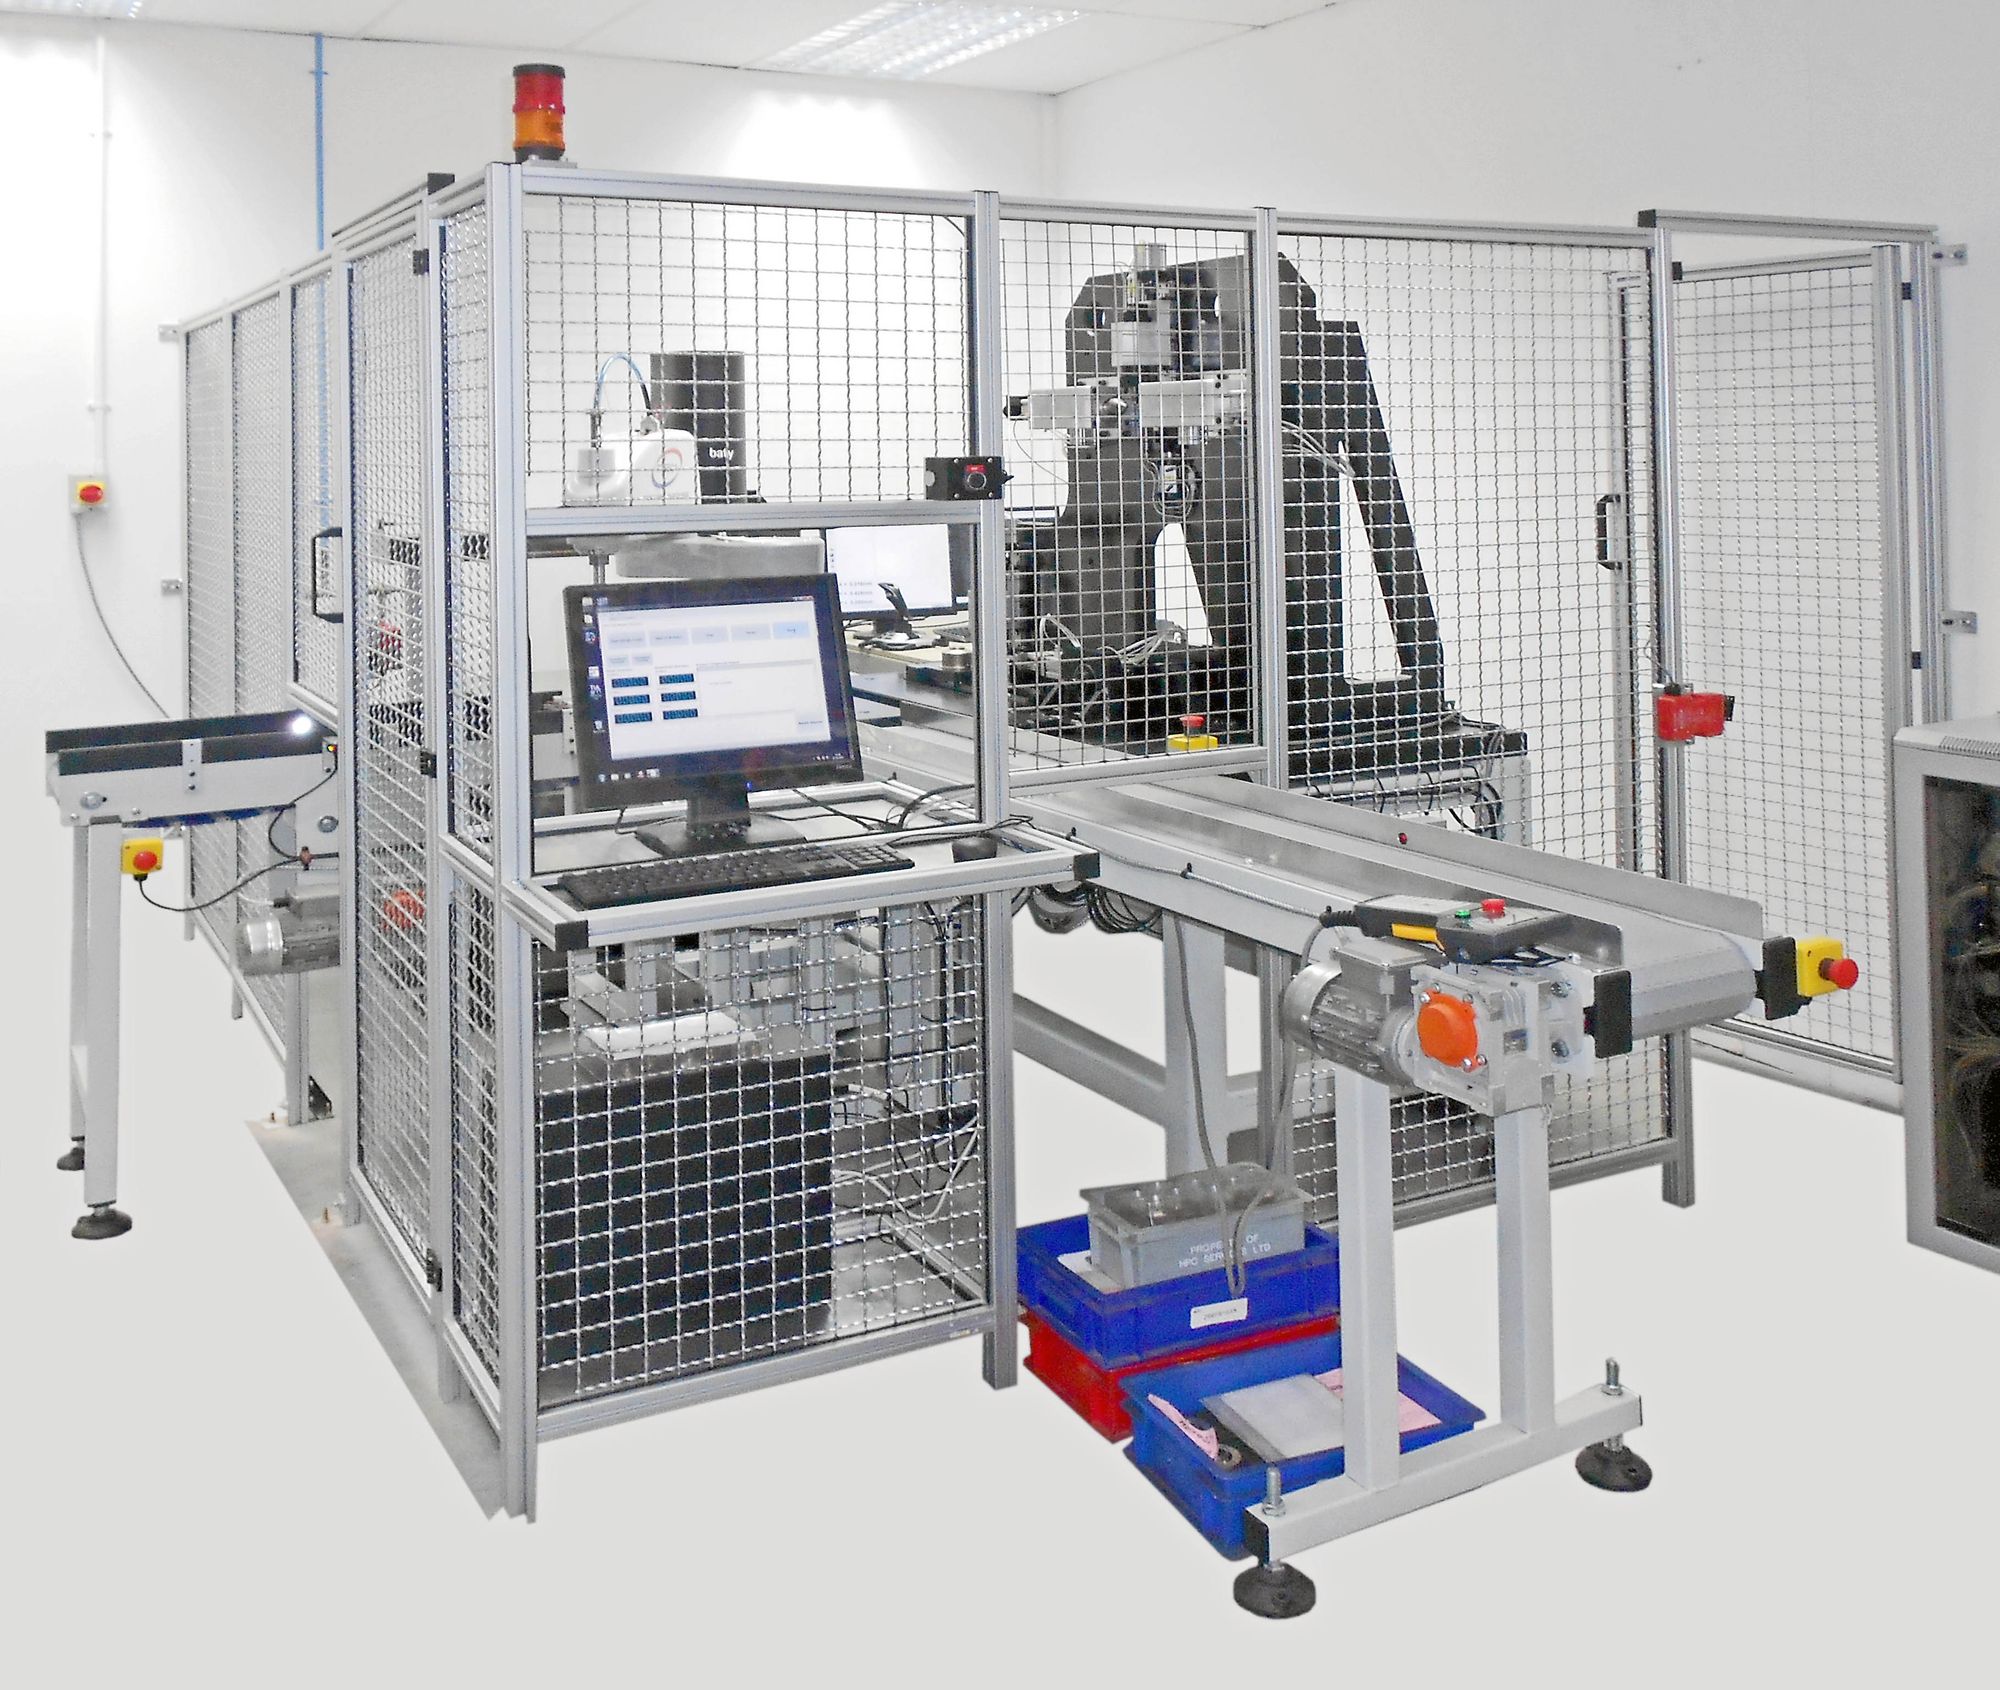
- 01Bearings are loaded onto an input conveyor that indexes until a part is detected in one of three vee locations.
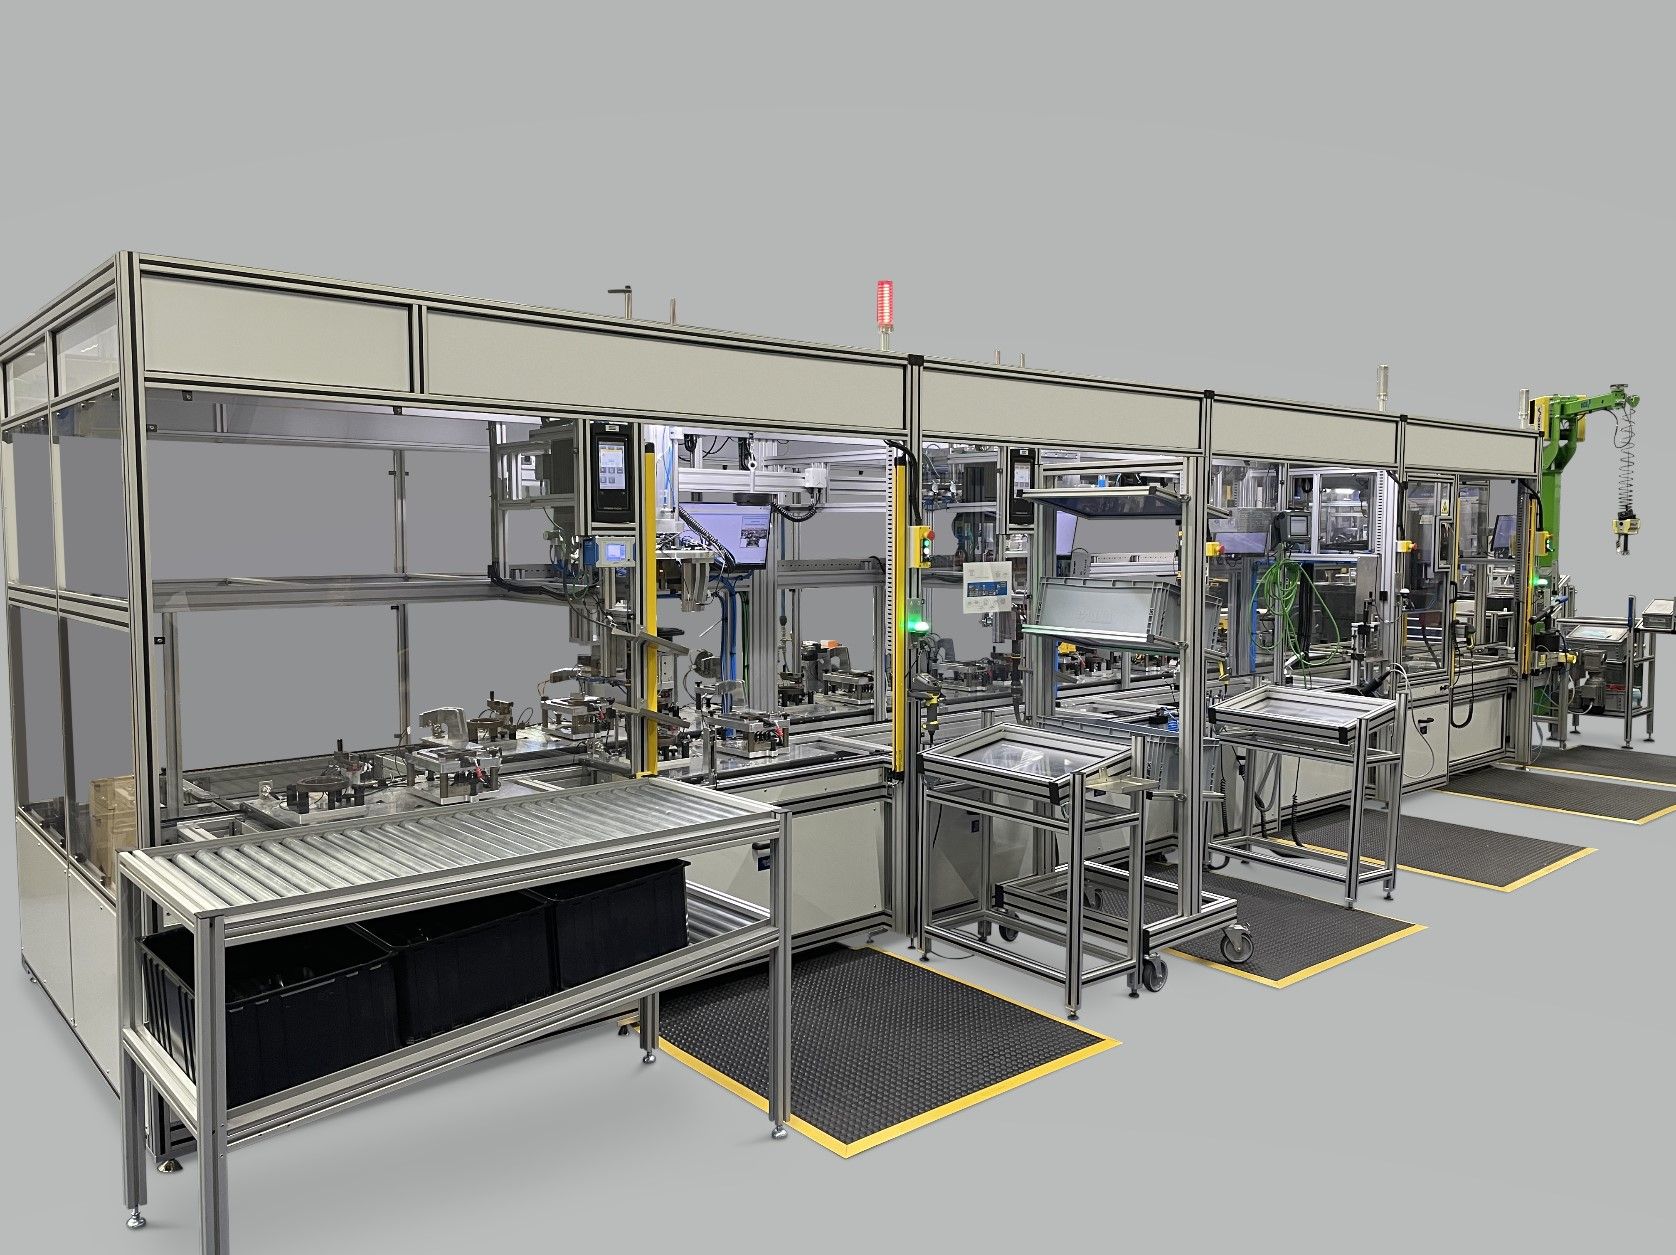
- 02A Toshiba SCARA robot loads the part onto a nest on the CMM for dimensional checks.
- 03The robot moves parts from the CMM to STT’s bespoke clearance checker, then to the pass or fail side of the output conveyor.
- 04Pneumatic pick and place units move the part between the axial and radial stations.
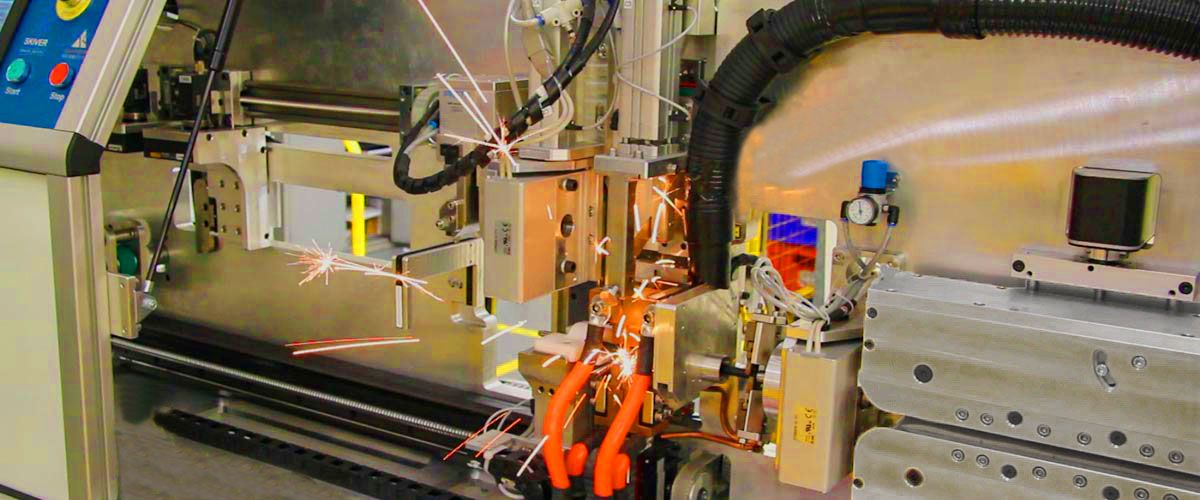
- 05The inner ball is pushed both ways and clearance measured from two linear transducers, with force controlled in closed loop by an electronic regulator and load cell.
Built with
- RobotToshiba SCARA
- MeasurementBaty CMM + STT clearance checker
- ControlSTT system: robot, CMM, PLC and PC software